Building a RoboCup Junior Soccer Robot
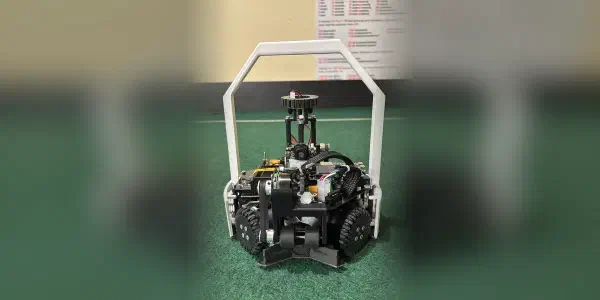
Team XLC – WYLDFYRE built two autonomous soccer robots around the ESP32-S3 and finished 11th of 24 at RoboCup Junior 2026 in Incheon. This article covers why we moved from an Arduino Mega to the ESP32-S3, how we read 48 analog line sensors through three multiplexers, how the whole robot runs from a millis-based scheduler inside loop(), and how ESP-NOW let two identical robots swap attacker and defender roles mid-match. It also covers what it cost us to use almost every usable pin on the chip, and the gate driver that destroyed several boards before we understood it.