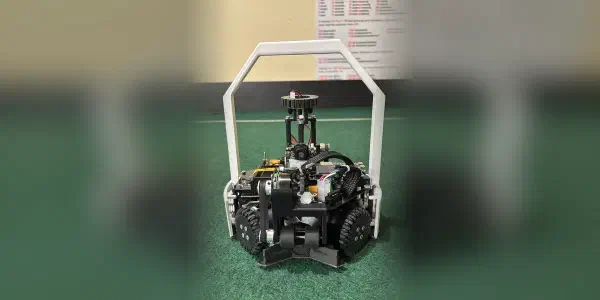
Team XLC – WYLDFYRE built two autonomous soccer robots around the ESP32-S3 and finished 11th of 24 at RoboCup Junior 2026 in Incheon. This article covers why we moved from an Arduino Mega to the ESP32-S3, how we read 48 analog line sensors through three multiplexers, how the whole robot runs from a millis-based scheduler inside loop(), and how ESP-NOW let two identical robots swap attacker and defender roles mid-match. It also covers what it cost us to use almost every usable pin on the chip, and the gate driver that destroyed several boards before we understood it.
This article introduces the ESP_Video library in the Arduino core for ESP32. It explains how the V4L2-style capture API works on MIPI-CSI and DVP camera interfaces, walks through hardware configuration and frame capture, and shows how to run the official examples on ESP32-P4 and ESP32-S3 boards.
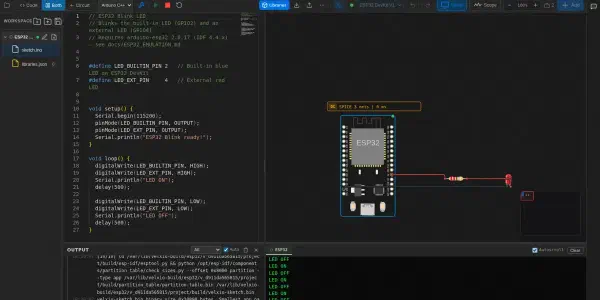
This article introduces Velxio, an open-source, browser-based embedded simulator that runs real ESP32 firmware on emulated hardware. It explains how the simulator works under the hood, demonstrates LED, Wi-Fi, MQTT, and sensor based projects, and highlights support for multiple boards across the ESP32 family.
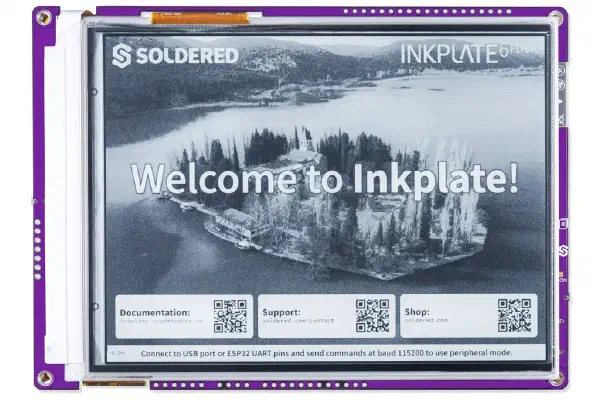
Inkplate is a family of all-in-one, open-source e-paper development boards built around the ESP32. This article introduces the Inkplate lineup, covers the hardware, the Arduino and MicroPython libraries, and the kinds of projects you can build, explaining why ESP32 makes e-paper development accessible for everyone.
A first-person account of building an ESP32-C5 Arduino temperature indicator with AI assistance, from generated code and confusing errors to serial debugging, wiring issues, and the moment the LED finally changed color.
Learn how to create, structure, and publish Arduino libraries for ESP32. This step-by-step guide covers everything from understanding a library structure to submitting your library to the Arduino Library Manager.
Learn how to set up the ESP32 Arduino Core development environment, including Arduino IDE installation and ESP32 board package setup using both the Board Manager and manual Git installation methods.
Announcing the version 3.0.0 of the Arduino Core for Espressif devices, as well the Arduino Component for ESP-IDF. Now, ESP32-C6 and ESP32-H2 are supported.